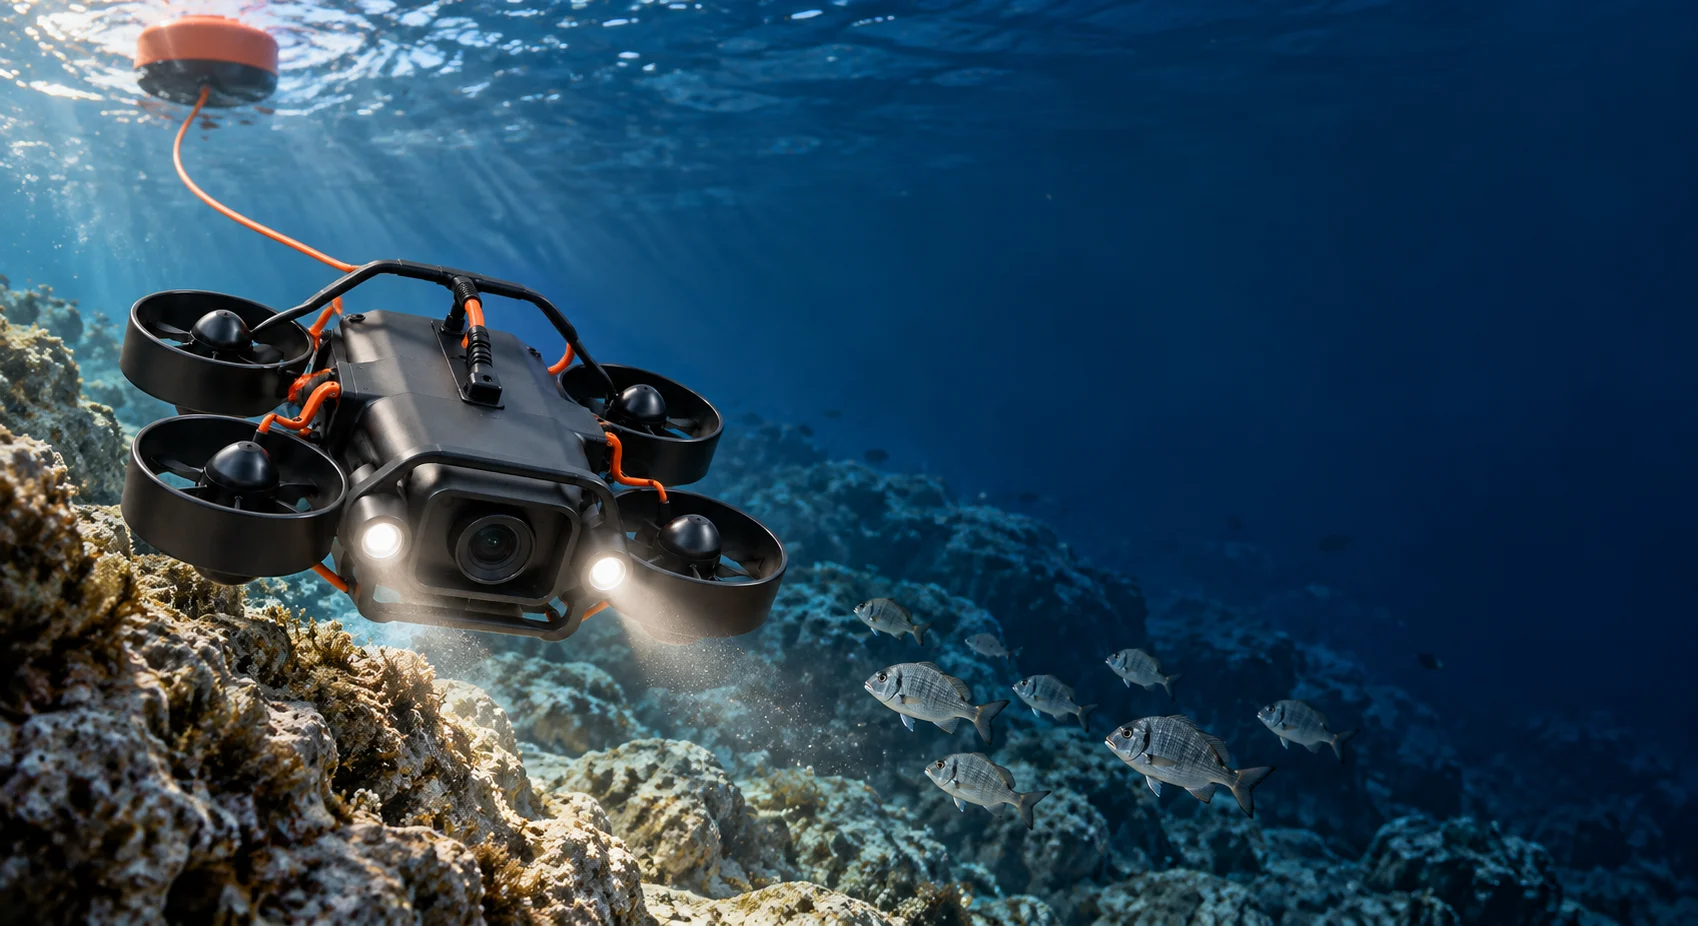
Four-thruster concept
Directional control with a focus on simple, familiar piloting.
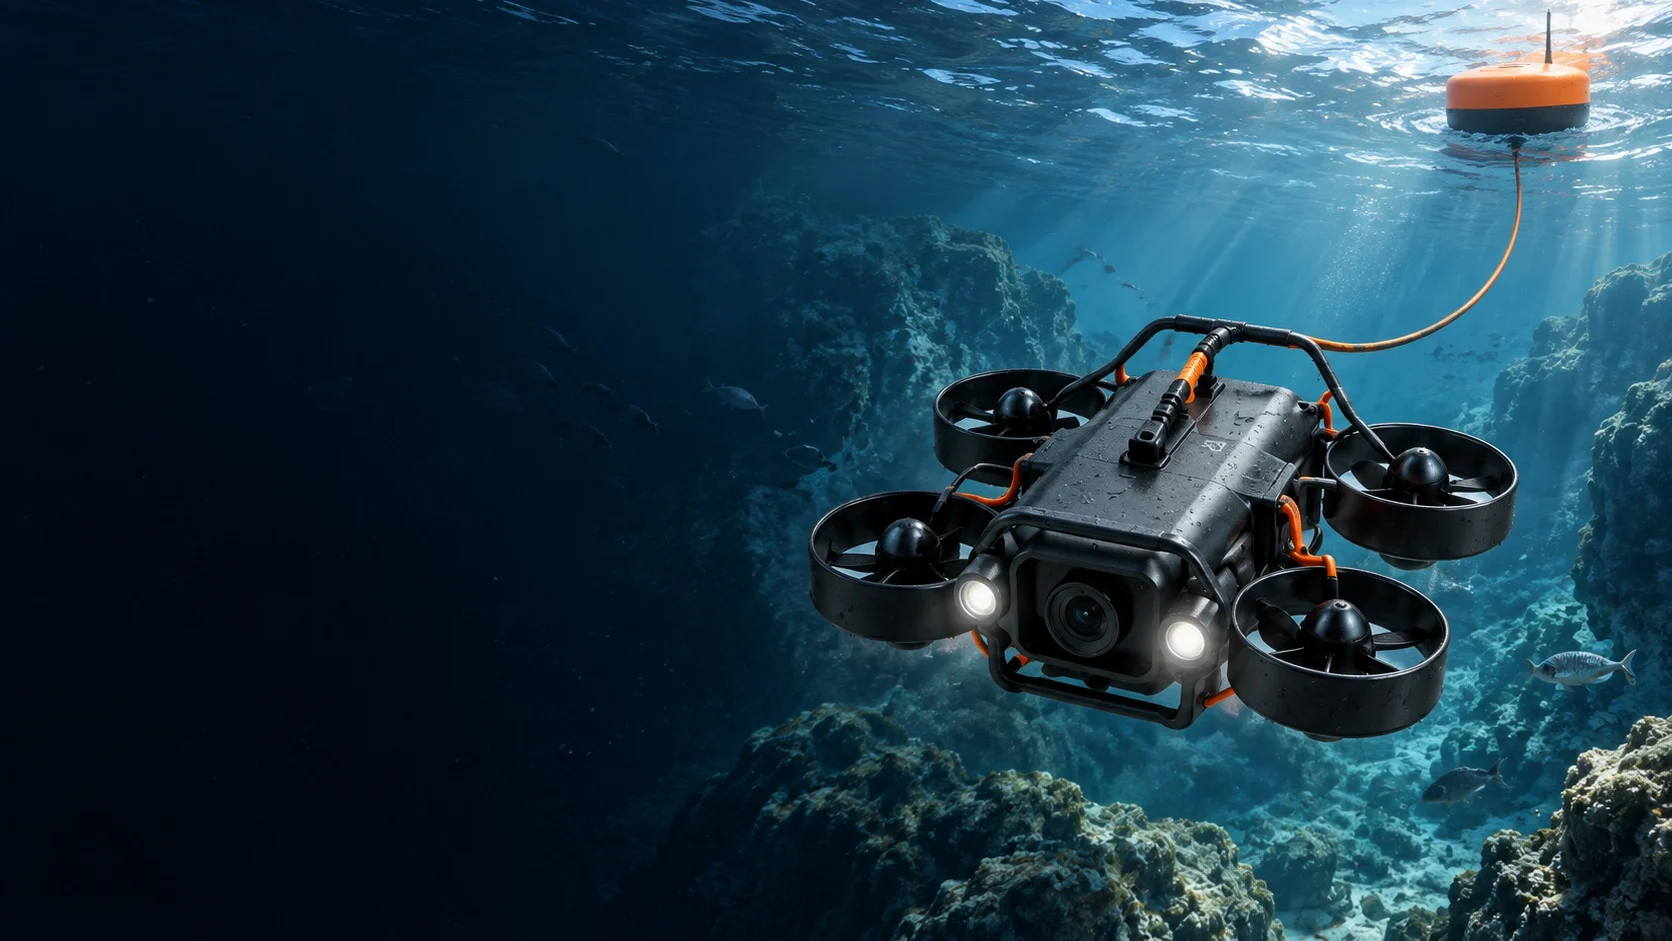
Underwater exploration Concept stage
A vision for exploring the underwater world
with a game controller, from anywhere.
The device
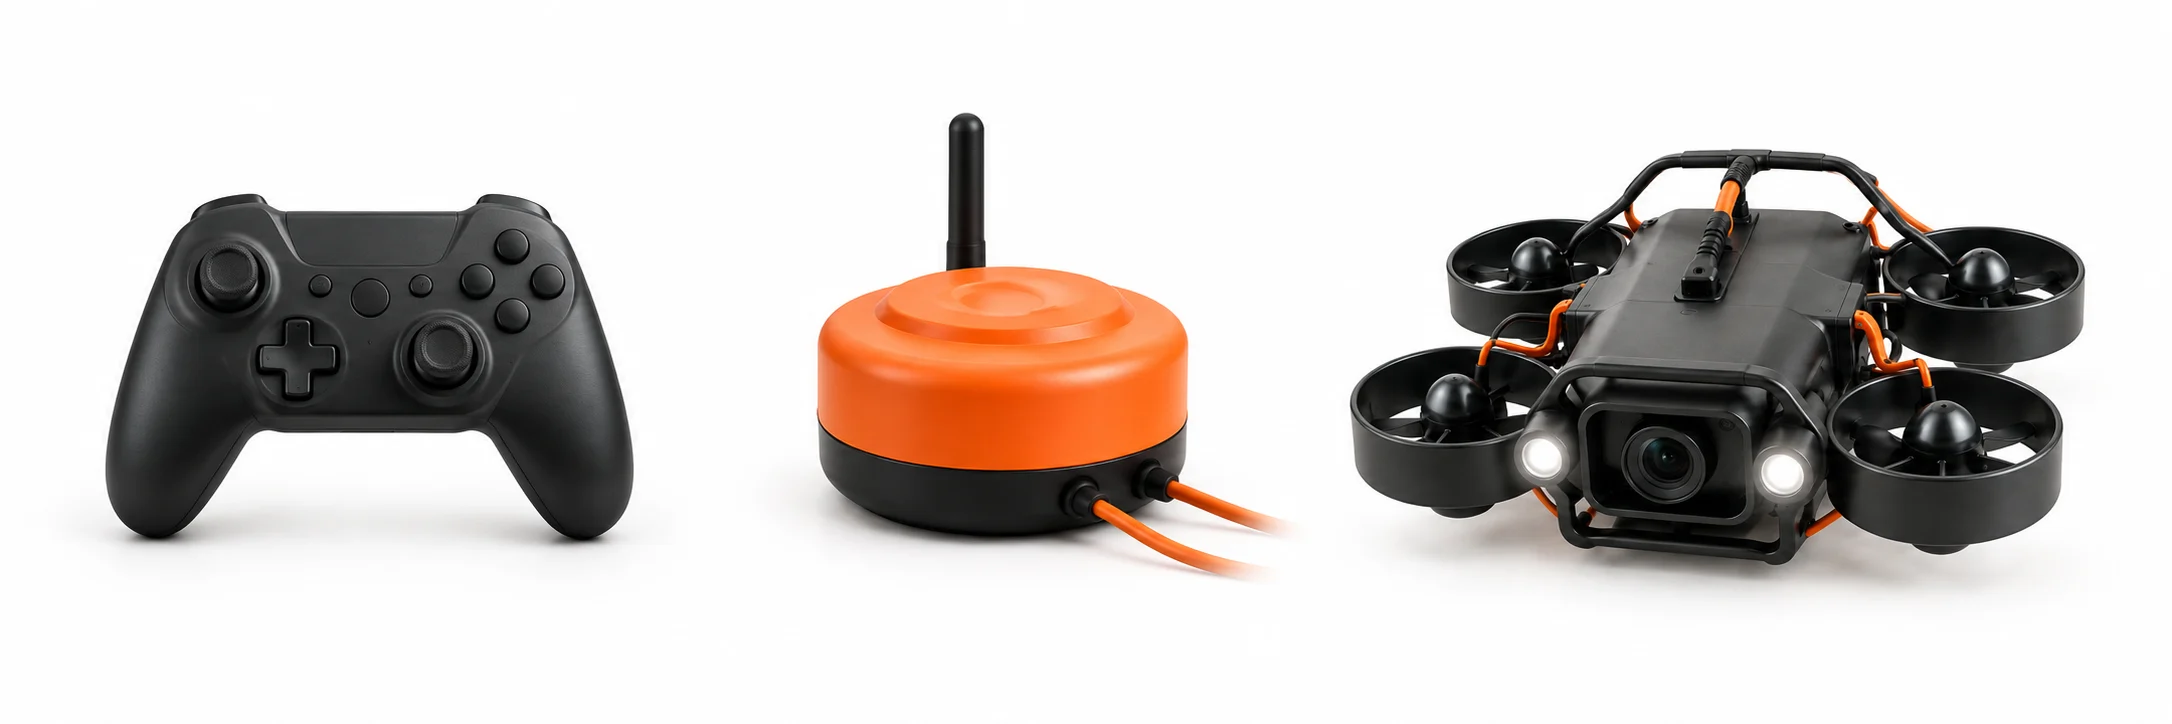
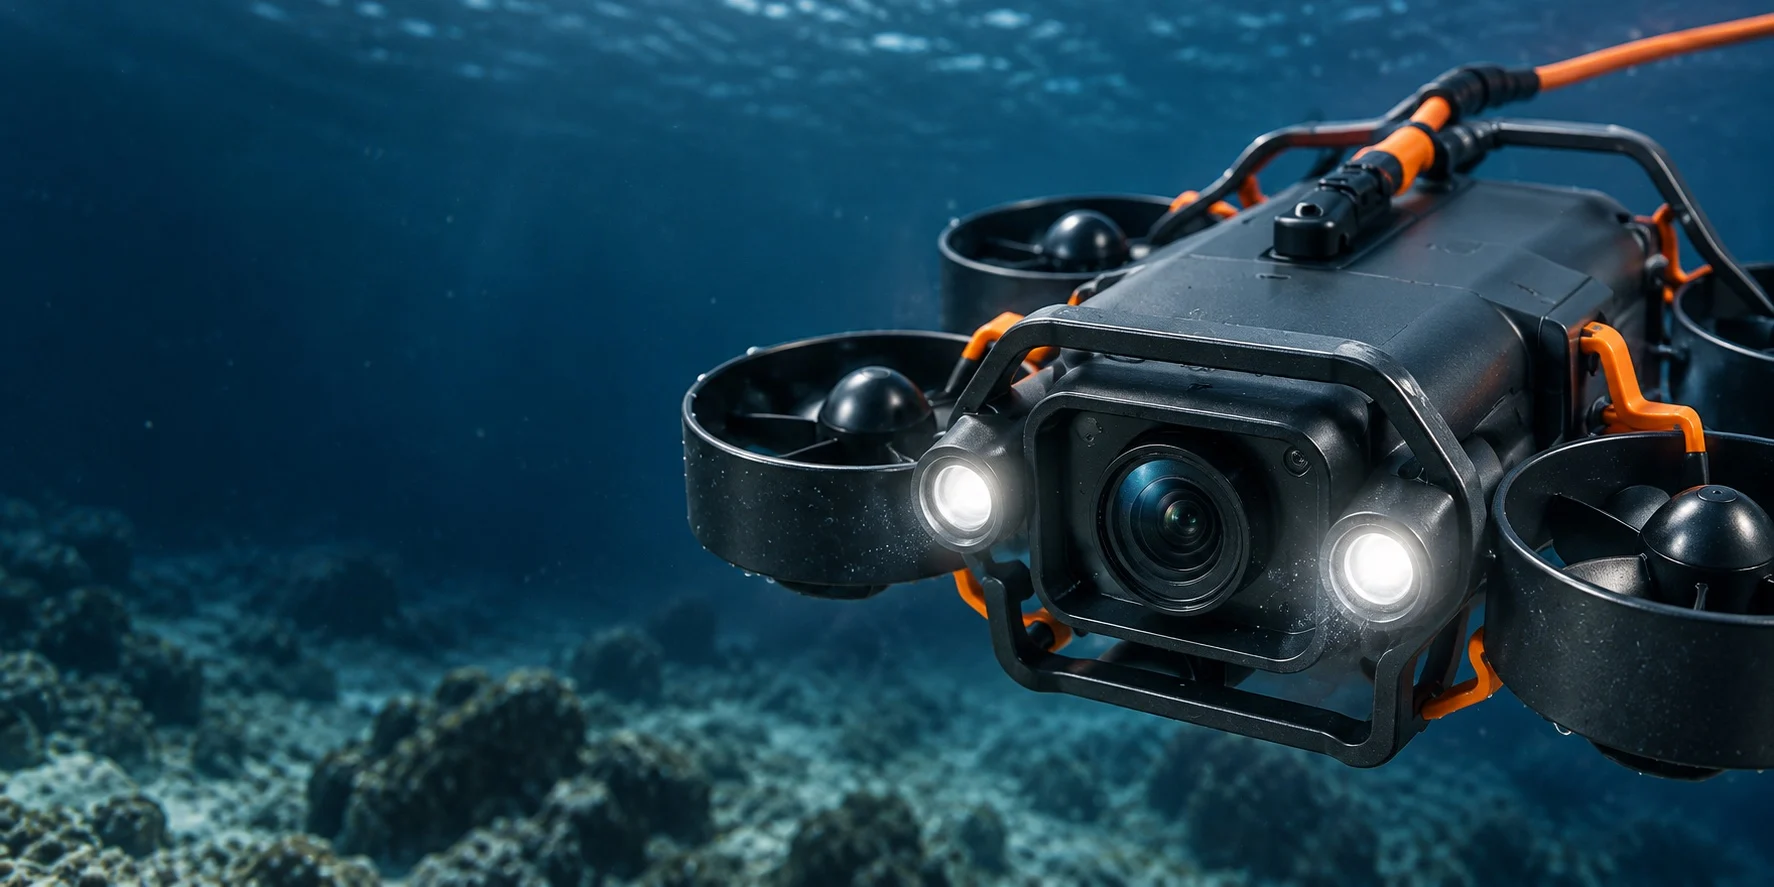
A compact underwater drone concept, built around a camera, a familiar controller and a simple connection to the surface.
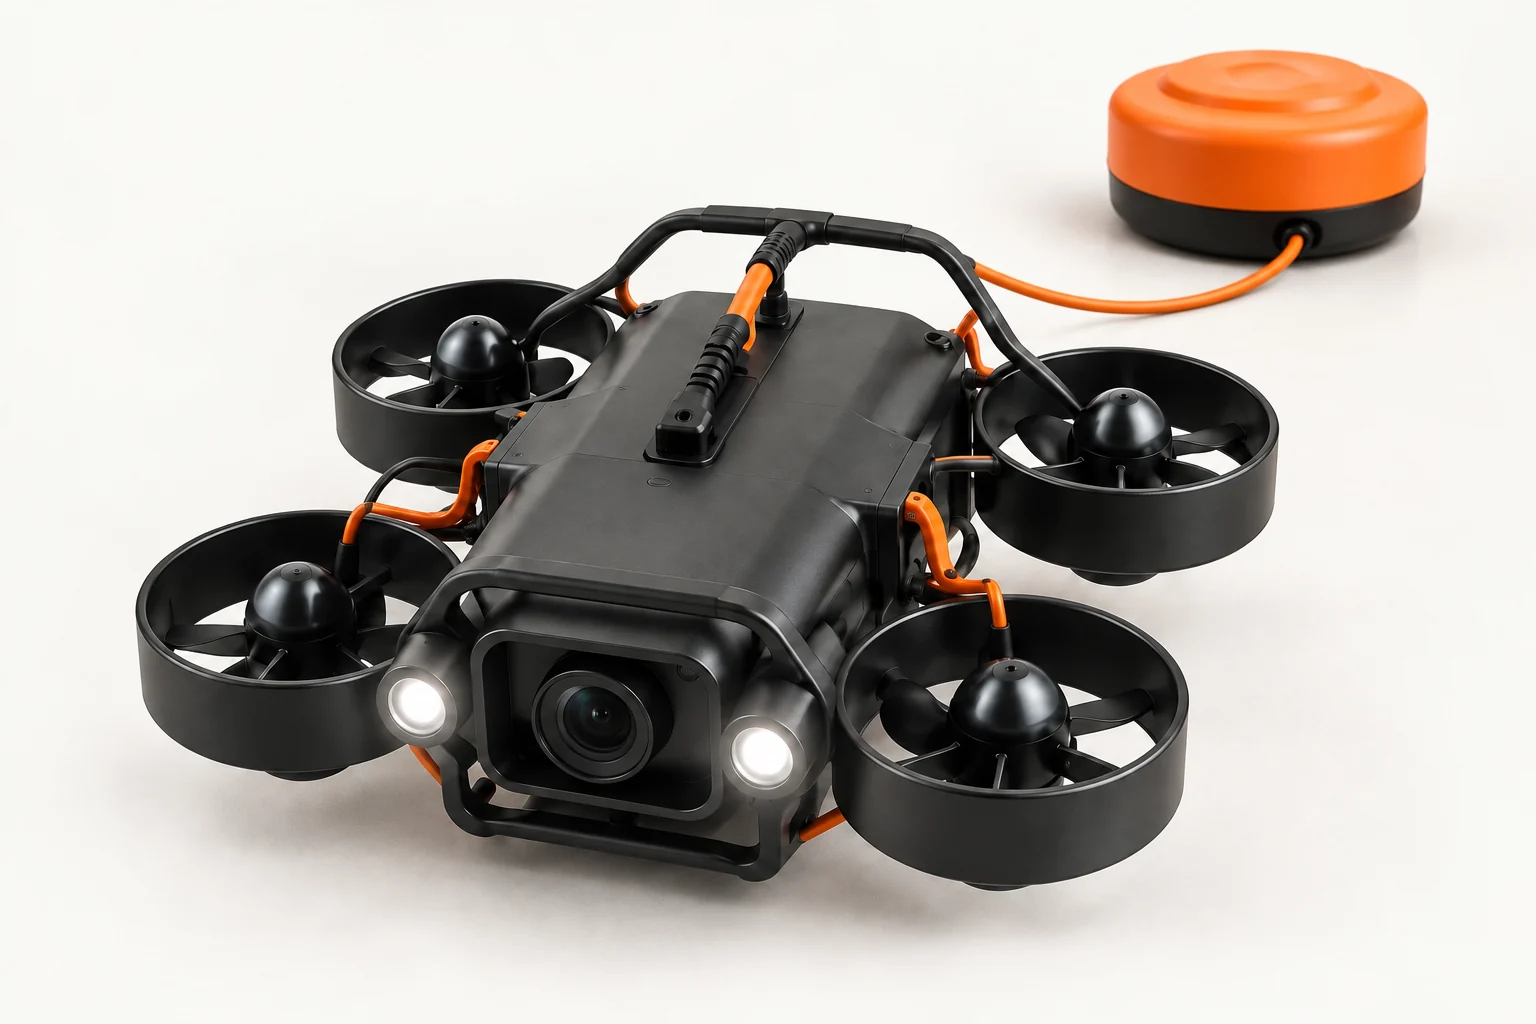
Directional control with a focus on simple, familiar piloting.
Live underwater imagery at the centre of the experience.
Replaceable parts, with room to explore new capabilities.
Pressure-balanced electronics and a repairable frame could bring costs down. Depth, endurance and production economics still need physical validation.
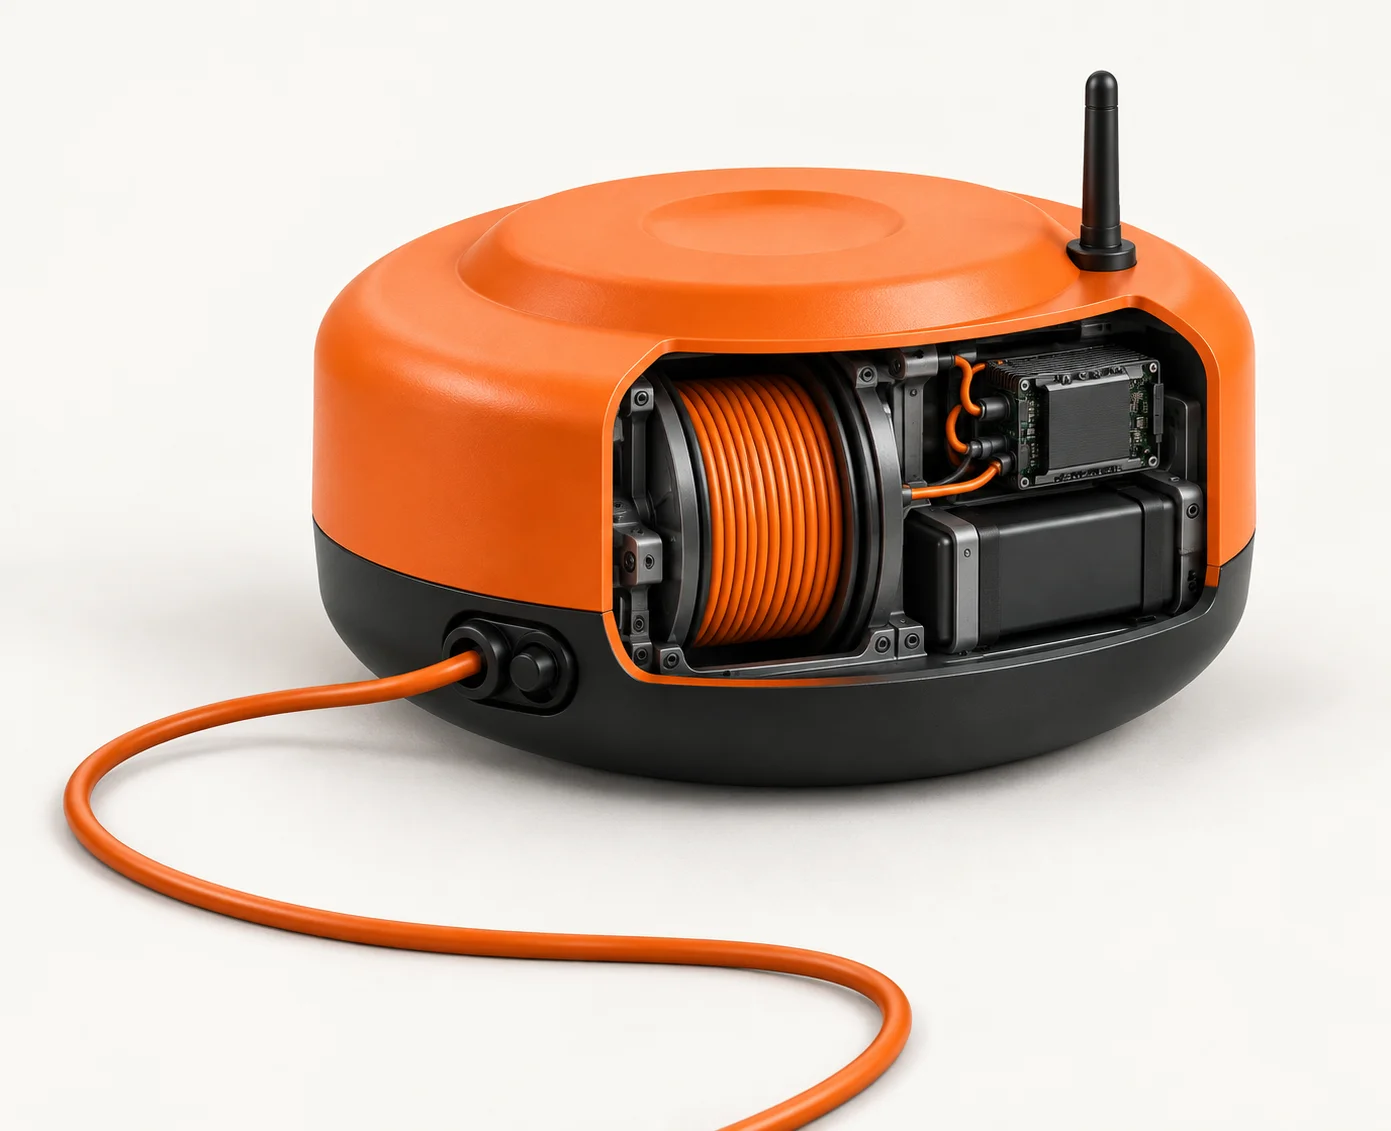
Above water. Connected below.
A compact companion for the cable, the connection and the next dive.
The surface hub concept brings together the tether connection, local Wi-Fi and a possible mobile-network uplink. An integrated reel is a packaging idea being explored to make cable storage and deployment part of the same portable system.
The vehicle would carry its own battery. The tether’s job is communication: control, video and telemetry. Early prototypes start with a practical wired setup, with lighter fibre options to explore later.
From a shore, pier or boat, the operator connects a controller and screen to the surface station. The tether carries video and movement commands to the drone. Local control is intended to remain useful without a cloud subscription or an internet connection.
On the water
One guest takes the controls. Others follow the underwater view on a big screen. A local operator brings the whole experience together.
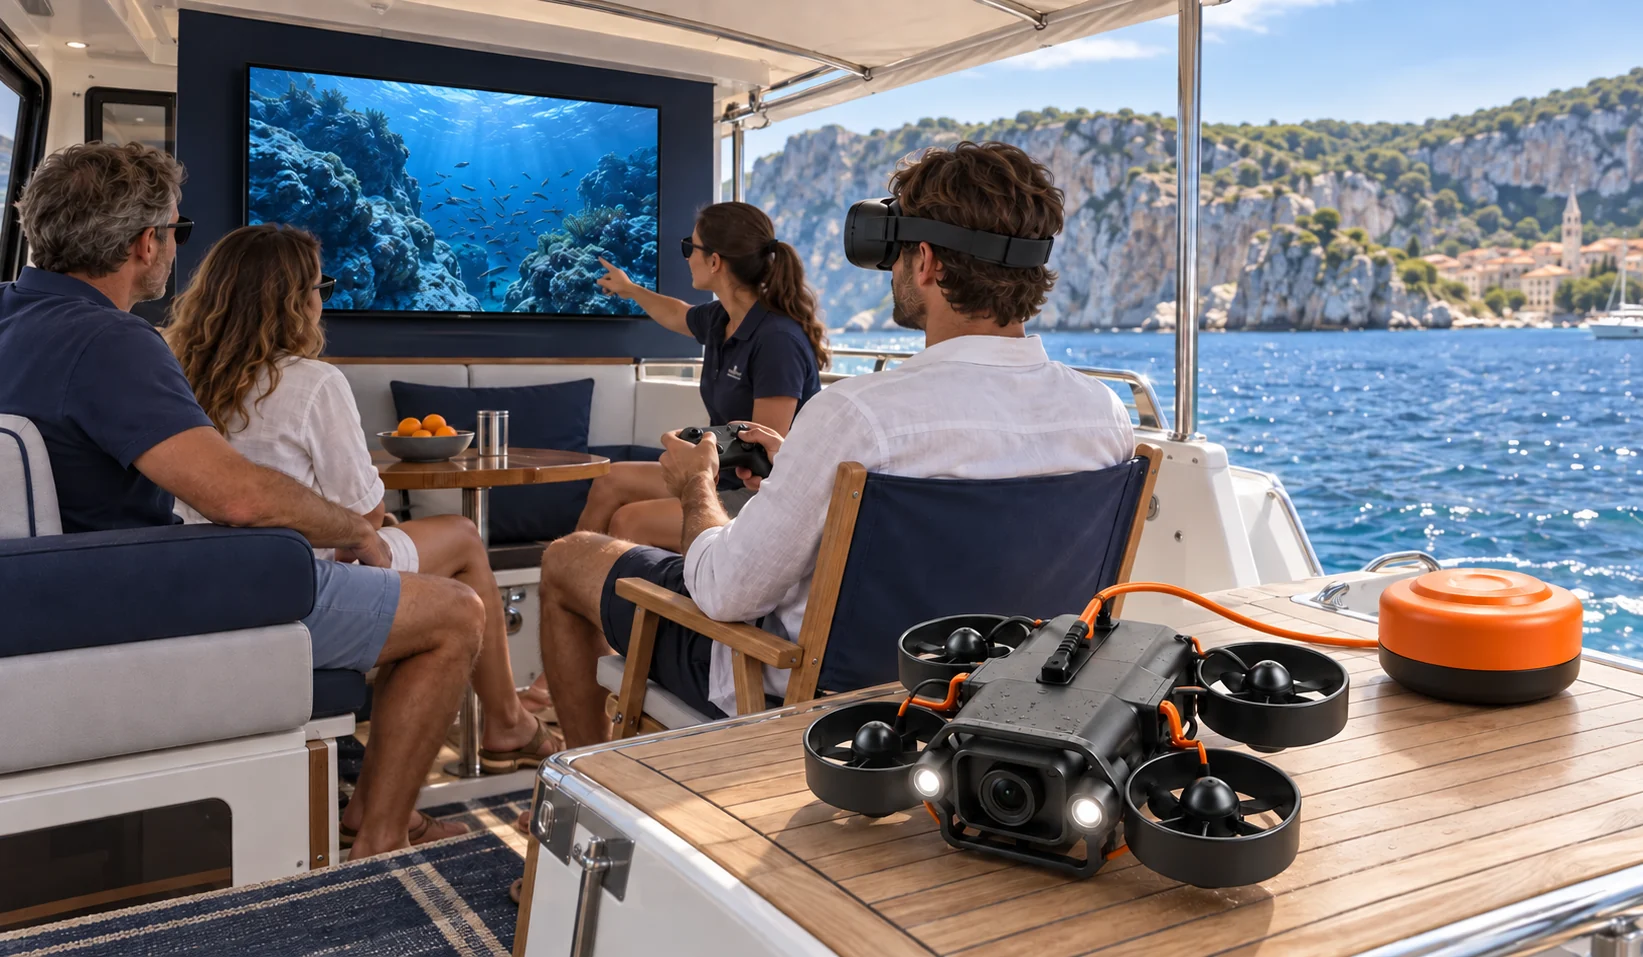
A headset could bring the underwater view into a personal virtual screen. A familiar controller gives the guest a way to explore.
An onboard TV keeps everyone part of the dive. Guests can spot marine life, suggest a direction and take turns piloting.
Operators could add guided underwater sessions to an existing excursion. Pricing and profitability are questions for commercial pilots.
The initial VR concept.
A later head-tracking experiment.
Future stereo-camera research.
An illustrative operator day
Local guests, remote pilots and viewers could make use of the same equipment at different times. Utilization has to be proven in real operations.
A sightseeing cruise, fishing trip or private charter could offer underwater exploration as an additional activity. Guests watch on a shared screen, try the controller or join a guided headset experience. The commercial pilot would test demand alongside preparation time, battery changes, maintenance and staff attention.
Potential income: hosted experiencesA starting point at the water’s edge
The concept also starts with a person, a controller and somewhere to launch.
Rocky coasts, lakes and marinas offer a different kind of exploration close to home. A portable setup could bring live underwater imagery to a nearby screen, without needing a boat.
Personal ownership is part of the idea from the beginning. Local piloting, recording and basic control are intended to stand on their own, with connected services adding options over time.
Proposed use cases depend on site suitability and operating conditions.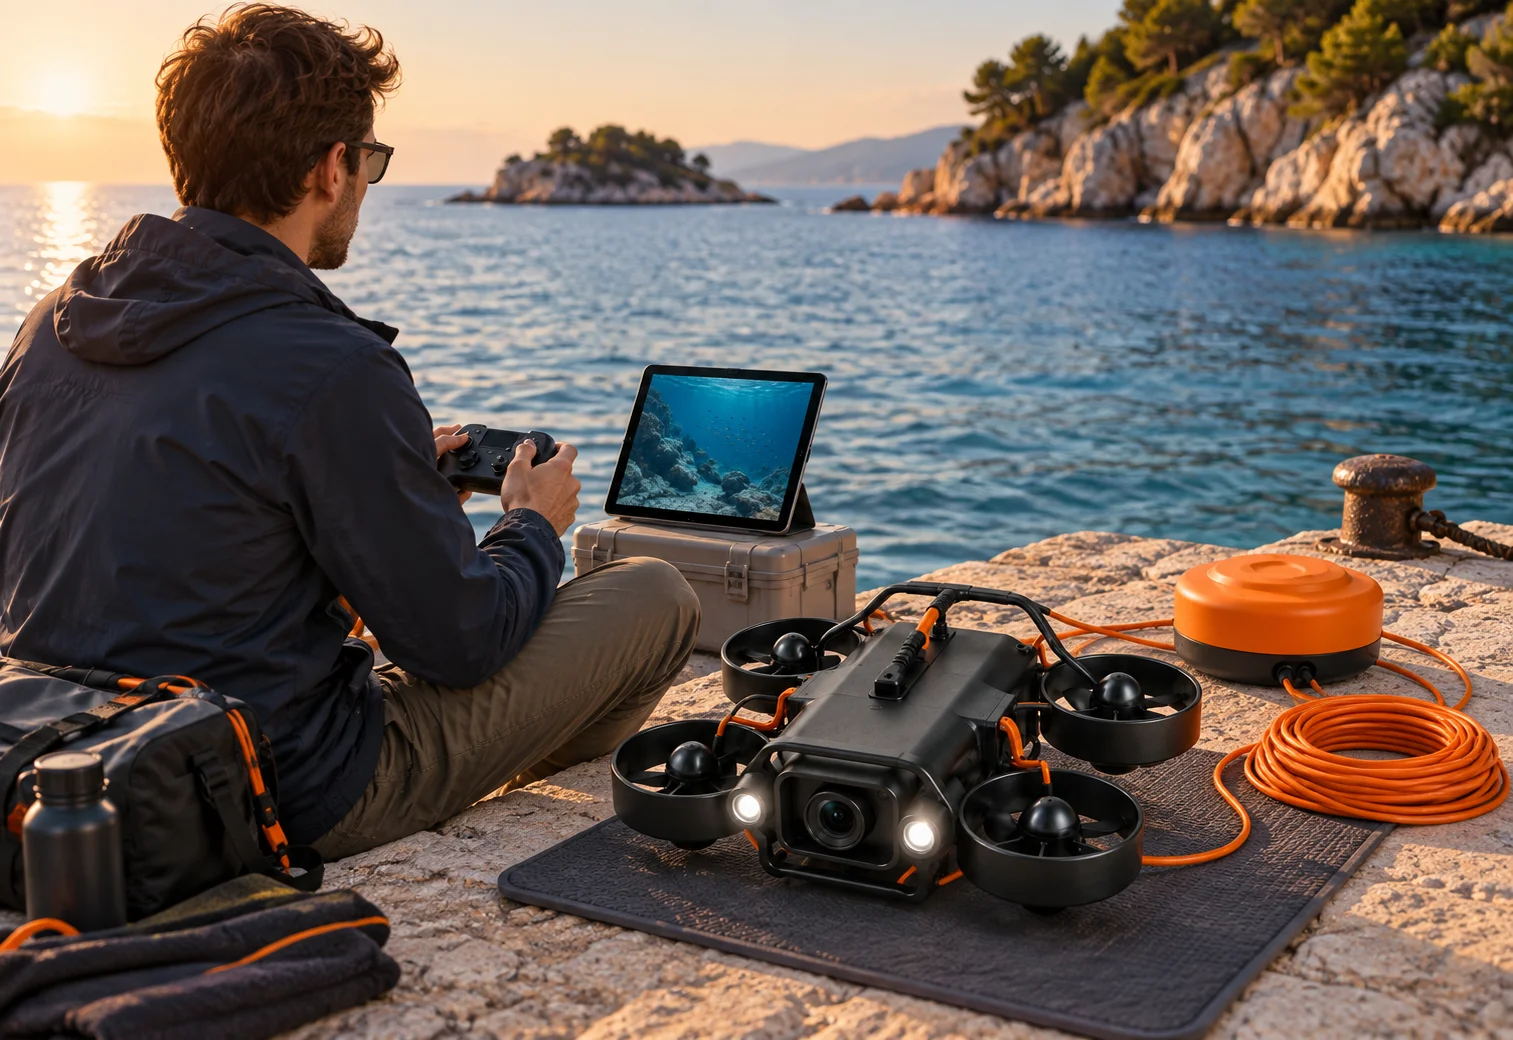
For private owners
There is another side to the cove you know. Remote Dive imagines a way to explore it from a small boat, a fishing skiff or a stationary personal watercraft.
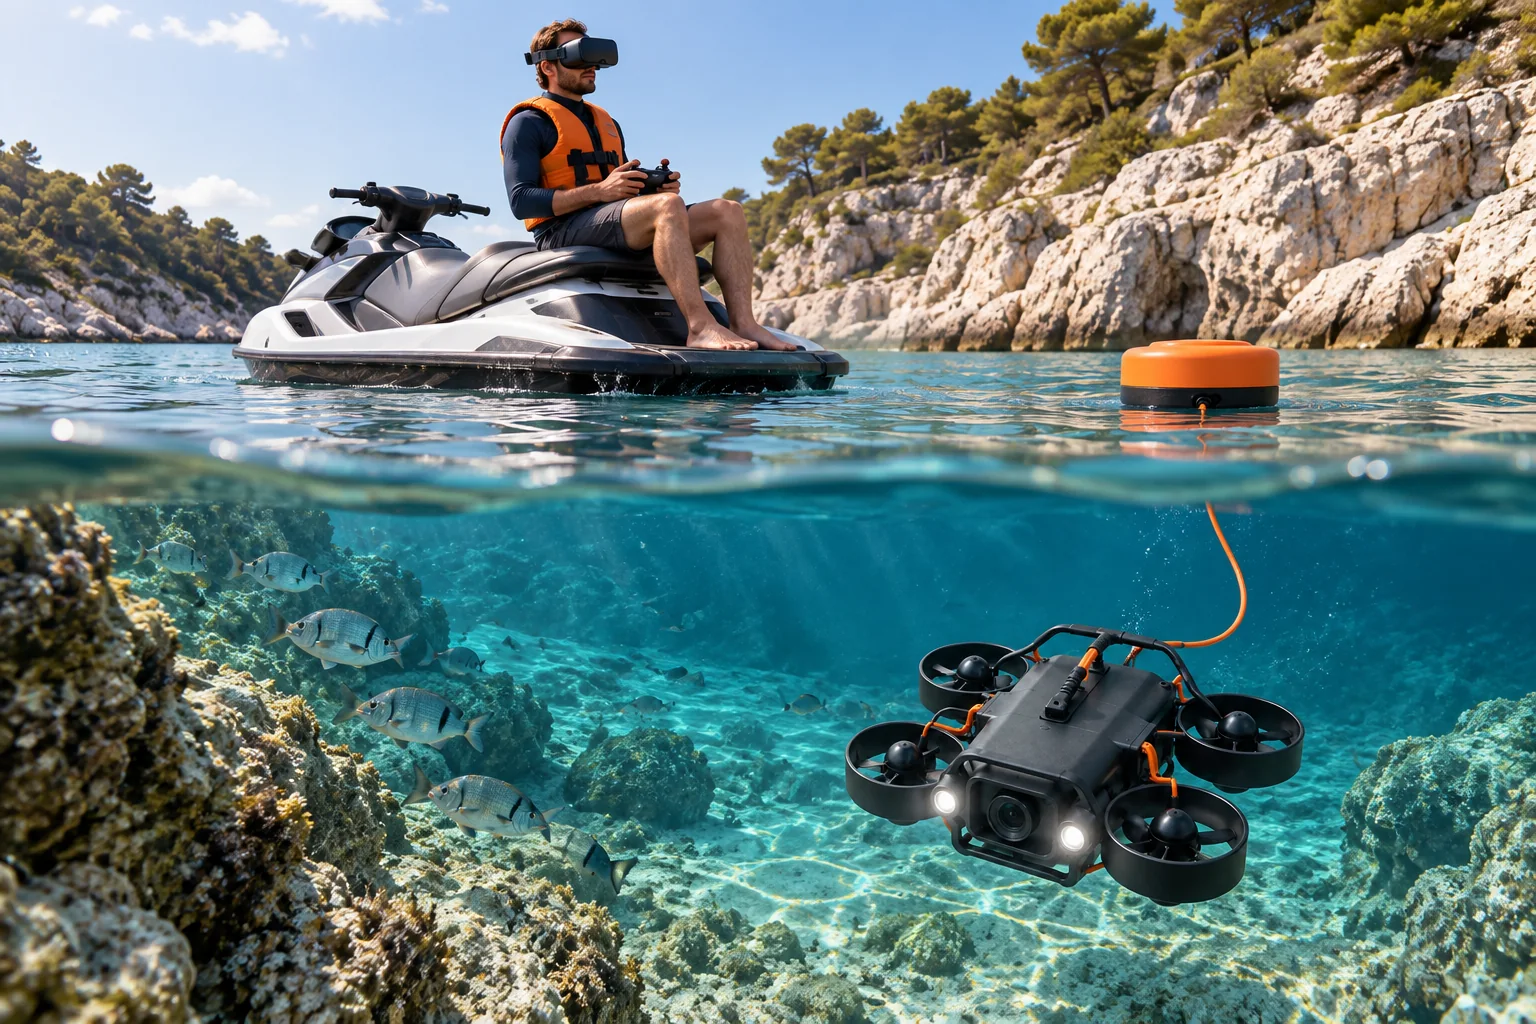
Reach a suitable spot, stop and look beneath the surface. The proposed setup brings a drone, a surface hub and a familiar controller together, with the underwater view on a screen or in a headset. The appeal starts with a place you want to explore yourself.
For someone who already hosts fishing trips or coastal outings, a guided dive could become an extra experience for passengers. A private owner could also explore hosting remote guests, handling the launch and recovery while someone elsewhere takes a turn at the controls.
Proposed use cases. The illustrated watercraft is stopped; the headset shows the drone’s view. Equipment and operating procedures still need field trials.
Explore beyond your own shore
Imagine a late night in Berlin while morning reaches the Thai coast. Settle into your chair, pick up a controller and join an underwater exploration on the other side of the world.
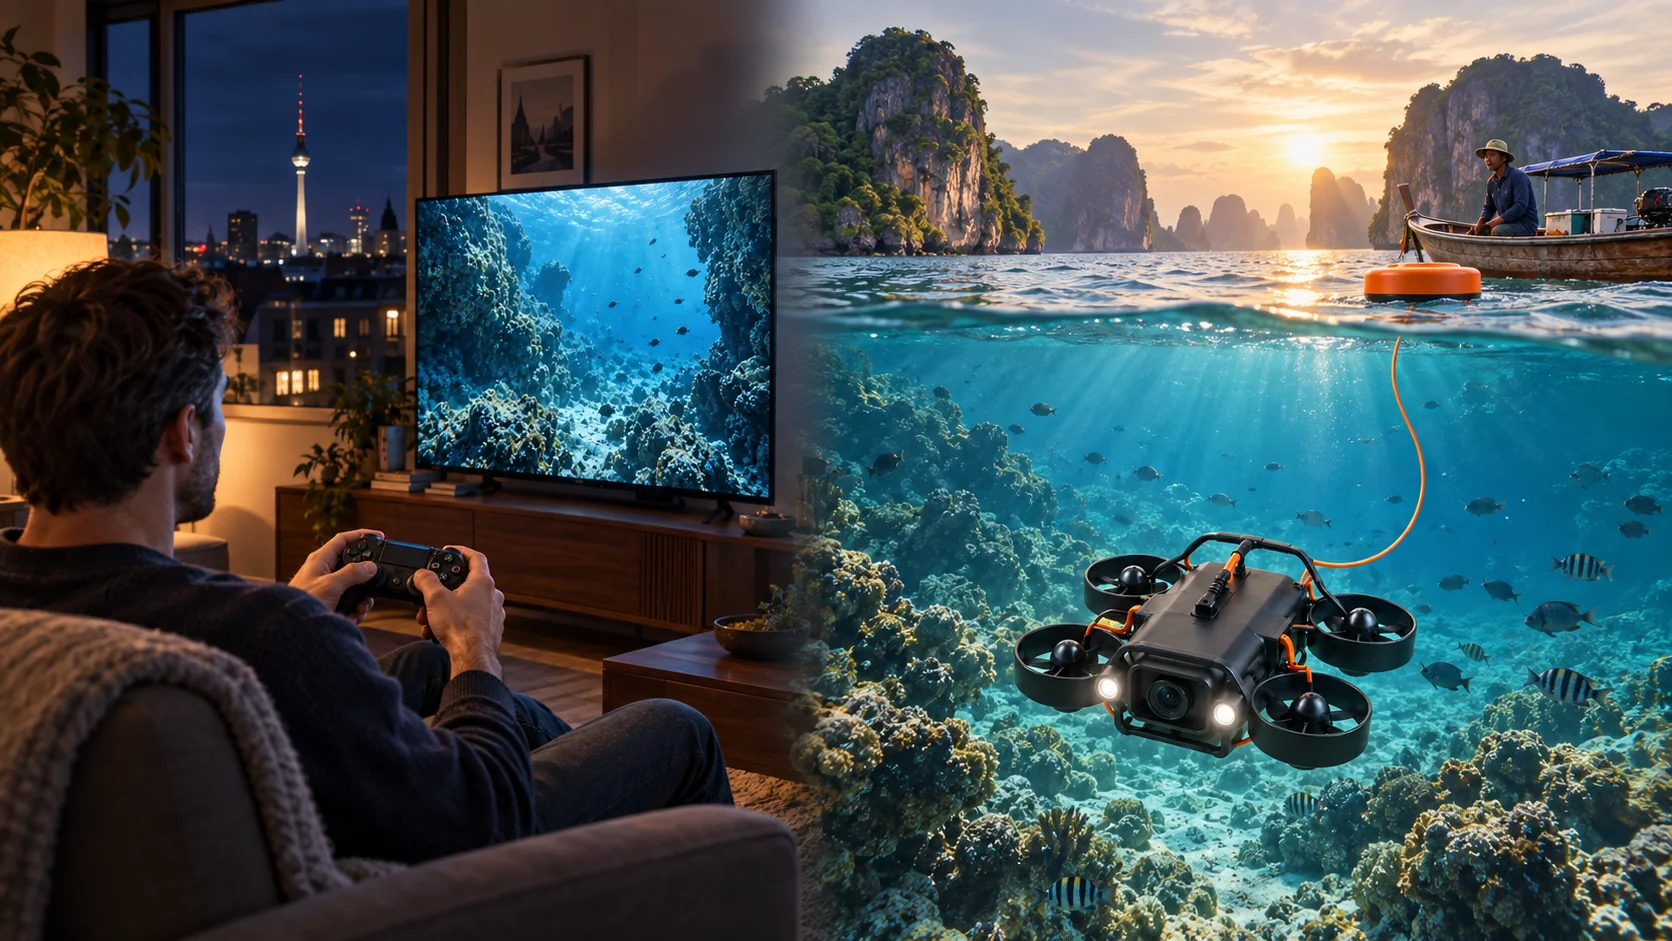 Concept visualization
Our aim is a network of places worth exploring: tropical reefs, rocky coves, lakes and marinas. Choose a location for the next session, follow a host who knows it, then discover a different shore another day.
At the controls, your gamepad would move a real underwater vehicle. A local operator would prepare, launch and recover it, with priority to take over. Each session depends on a ready operator, a suitable connection and conditions at the site.
Concept visualization of a future network. Berlin and Thailand illustrate the idea; locations and sessions are not yet available.
Remote control. Local responsibility. Stabilization is designed to run onboard. The field operator retains priority.
Proposed session formats
Public viewing creates a way in. Paid control reserves something physical: time with a real drone at a real place.
Public viewing would let people discover a location and share the underwater view before deciding whether to participate. A broadcast can serve a wider audience while control remains with one authorized pilot.
The pilot’s video connection and the public broadcast are separate parts of the proposed system. No sessions are available to book yet.
The people behind a dive
One person can take several roles. Separating them creates room for local businesses, remote hosts and owners to participate in different ways.
An owner could use the drone personally or place it with a local operator. Ownership need not require living near the deployment site.
Stores, charges, checks, launches and retrieves the equipment. This person monitors local conditions and retains priority control.
Welcomes participants, guides the conversation and manages the pilot queue. A host could run a session from another location.
Receives control for an authorized part of the session. The pilot chooses where to look and how to move within the mission’s limits.
Follows the underwater view and can become a participant. Watching, talking and requesting a turn are part of the social concept.
Hardware ownership, site operations, hosting and temporary control are distinct responsibilities.
The opportunity
Someone knows the cove. Someone has a boat. Someone else wants to see what is below. The proposed network connects these roles: independent local operators bring equipment and knowledge of a place; remote participants bring curiosity and demand.
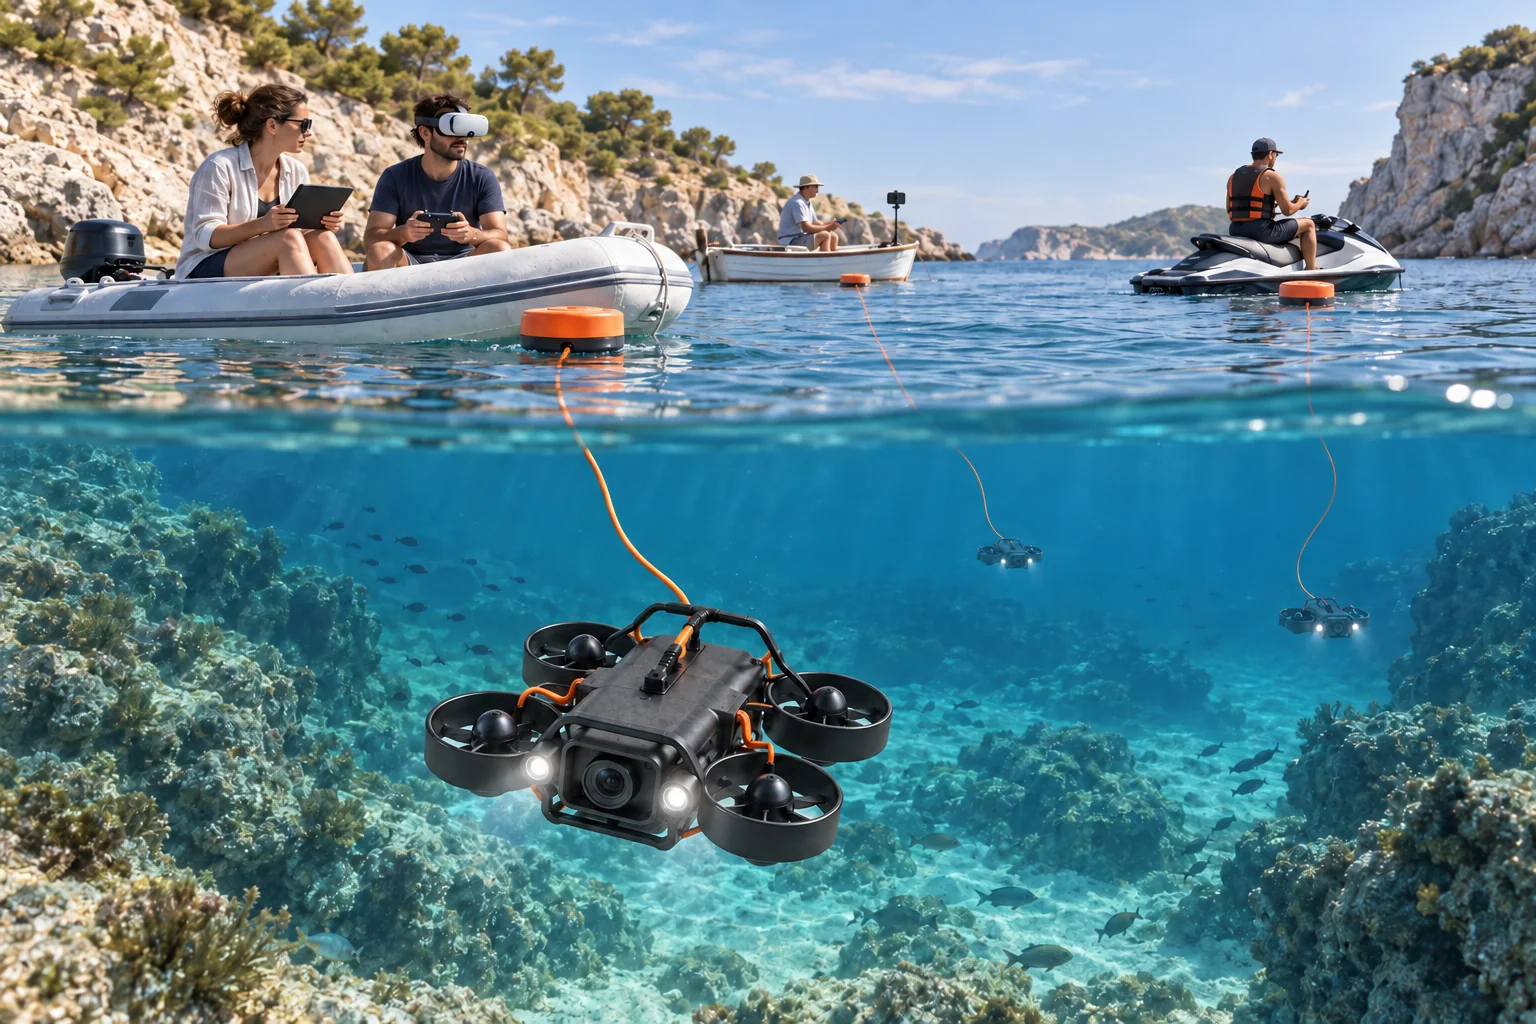 Concept visualization
A repairable drone for personal exploration and commercial use. Hardware and accessories form the starting business model.
Hardware & accessoriesA small-boat owner, fishing guide or dive centre could host the next underwater outing. The local operator prepares the equipment, handles launch and recovery and stays responsible for conditions at the site.
Tourism & local operatorsPaid time at the controls would give remote participants access to real places, with shared viewing and guided sessions.
Remote sessionsIndependent owners could add locations at their own pace. Public streams introduce each place, while bookings and paid sessions could support both the operators and the platform.
A future marketplaceA proposed business model. Customer demand and operating economics remain to be tested.
The business, in stages
The business model develops with the installed base. Each additional service should answer a real need discovered in use.
Drones, accessories, replacement parts and commercial kits are the initial revenue directions. Repairability matters to individual owners and to operators preparing equipment for another day on the water.
Tourism experiences and paid piloting sessions could create income around each deployment. The proposed platform could earn transaction fees while owners, operators and hosts agree how to share the work and proceeds.
Fleet management, archives, creator tools and optional cloud features become relevant when enough people are using the system. The design principle is that basic local ownership remains useful without a mandatory subscription.
Unit economics remain to be measured: demand, utilization, staff time, network costs, servicing and equipment life all matter.
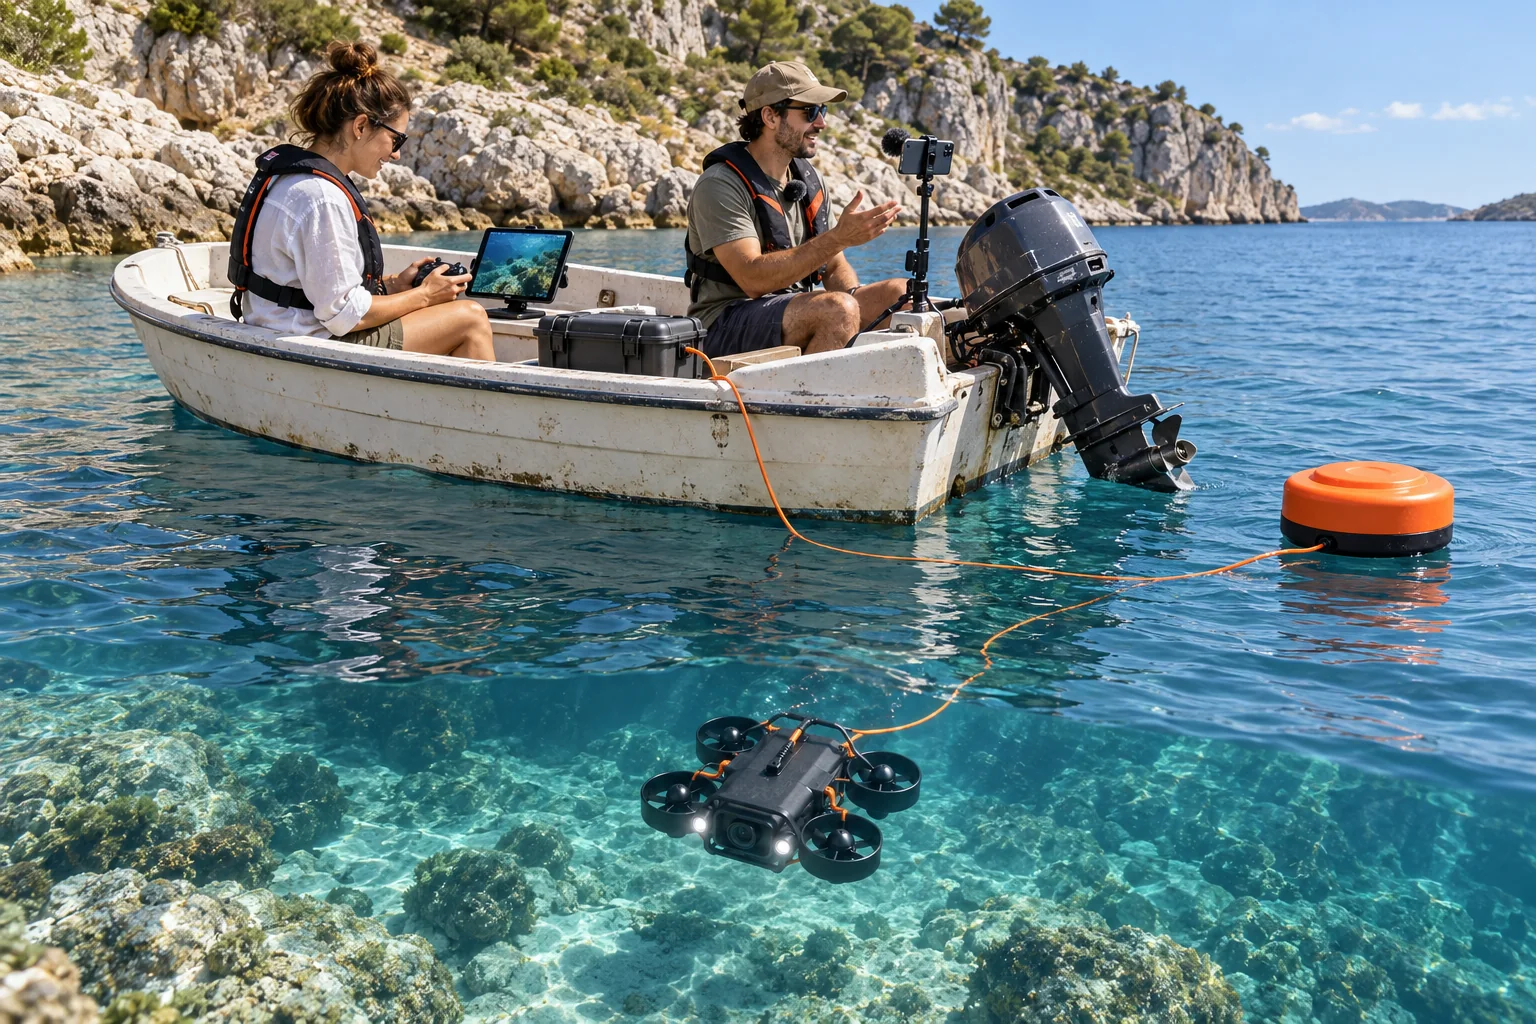
An expedition with an audience
A familiar cove could become the setting for a regular underwater show. One person pilots the drone; another tells the audience what is coming into view. A small motorboat becomes the base for the story.
Live streams on YouTube and short recordings of dives could bring an audience back to a particular place and host. Scheduled explorations, guest pilots and conversations with viewers give each outing a different story.
Viewer support, paid events and sponsorships could become another income stream. Audience interest, platform eligibility and production costs would need to be tested before treating it as a business.
A proposed dive journal
A fish, an old anchor, a new detail.
Keep the moment and its context.
Revisit a clip or snapshot.
Let others follow the discovery.
More people. More perspectives.
A teacher, a local operator and a room of curious students could share the same underwater view. Remote participation opens possibilities beyond tourism.
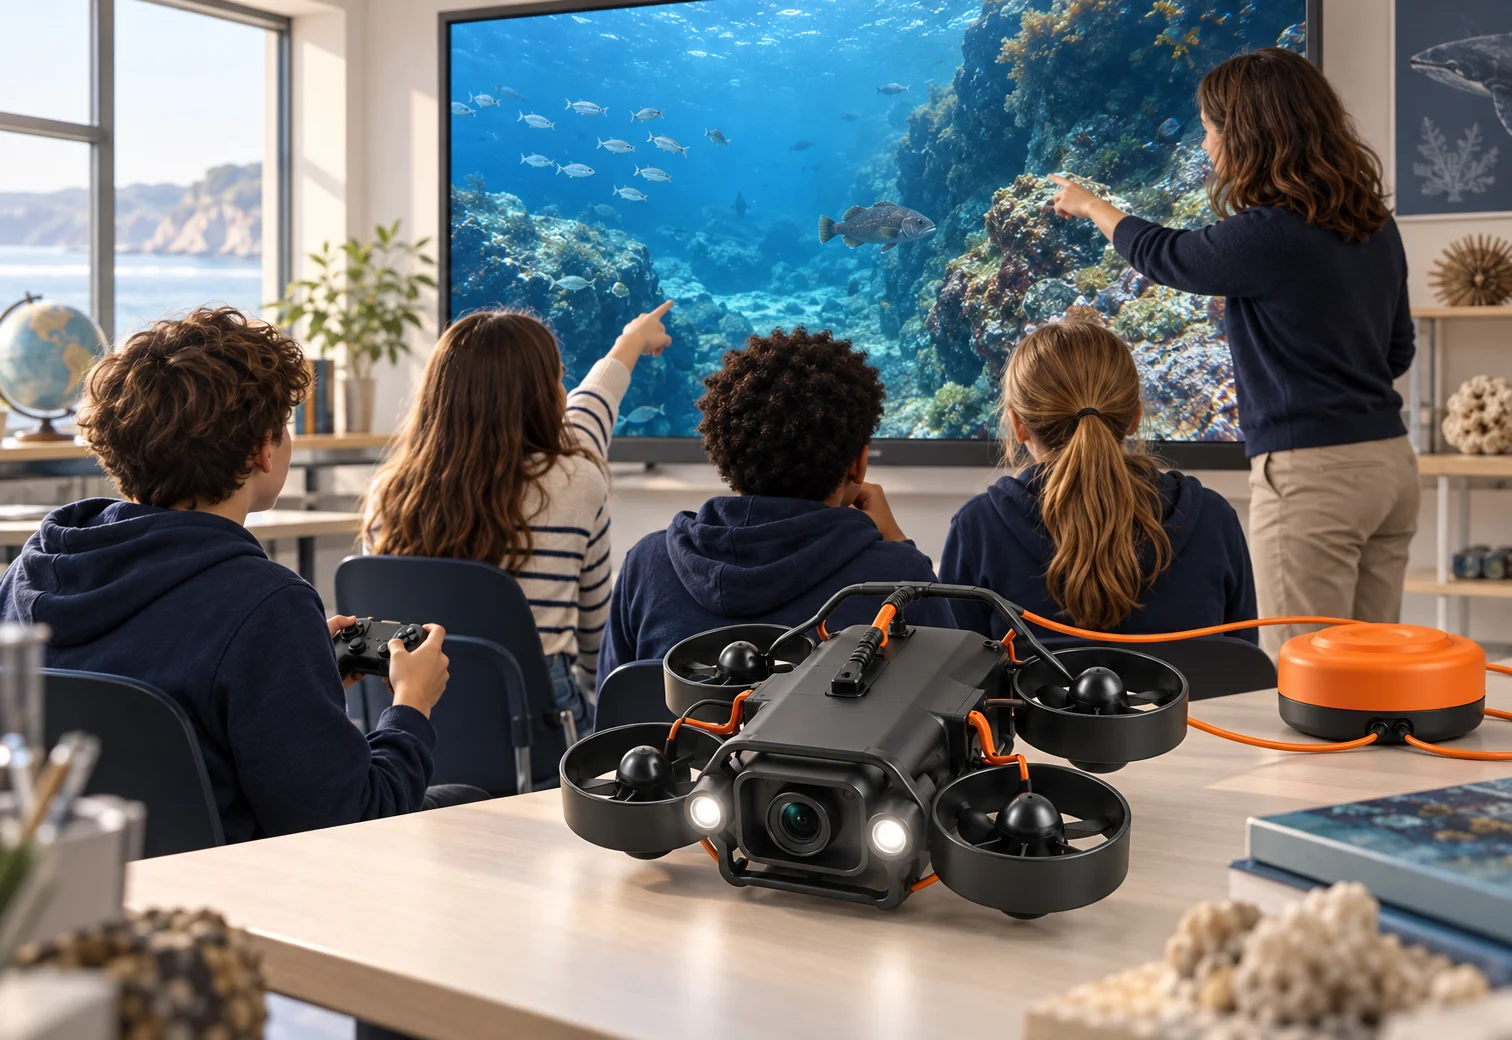
A teacher could host a remote field trip while students observe and take turns exploring. Marine biology, ecology and robotics are natural subjects for early educational pilots.
Researchers could join a shared session, discuss features and add observations. With permission, future dives might contribute records of habitats, species or underwater litter.
Marinas and boat owners could explore visual inspection use cases. Sonar, measurement and mapping are possible later modules, with their own hardware and validation needs.
Potential applications, not existing deployments or validated scientific and educational outcomes.
Built to be worked on
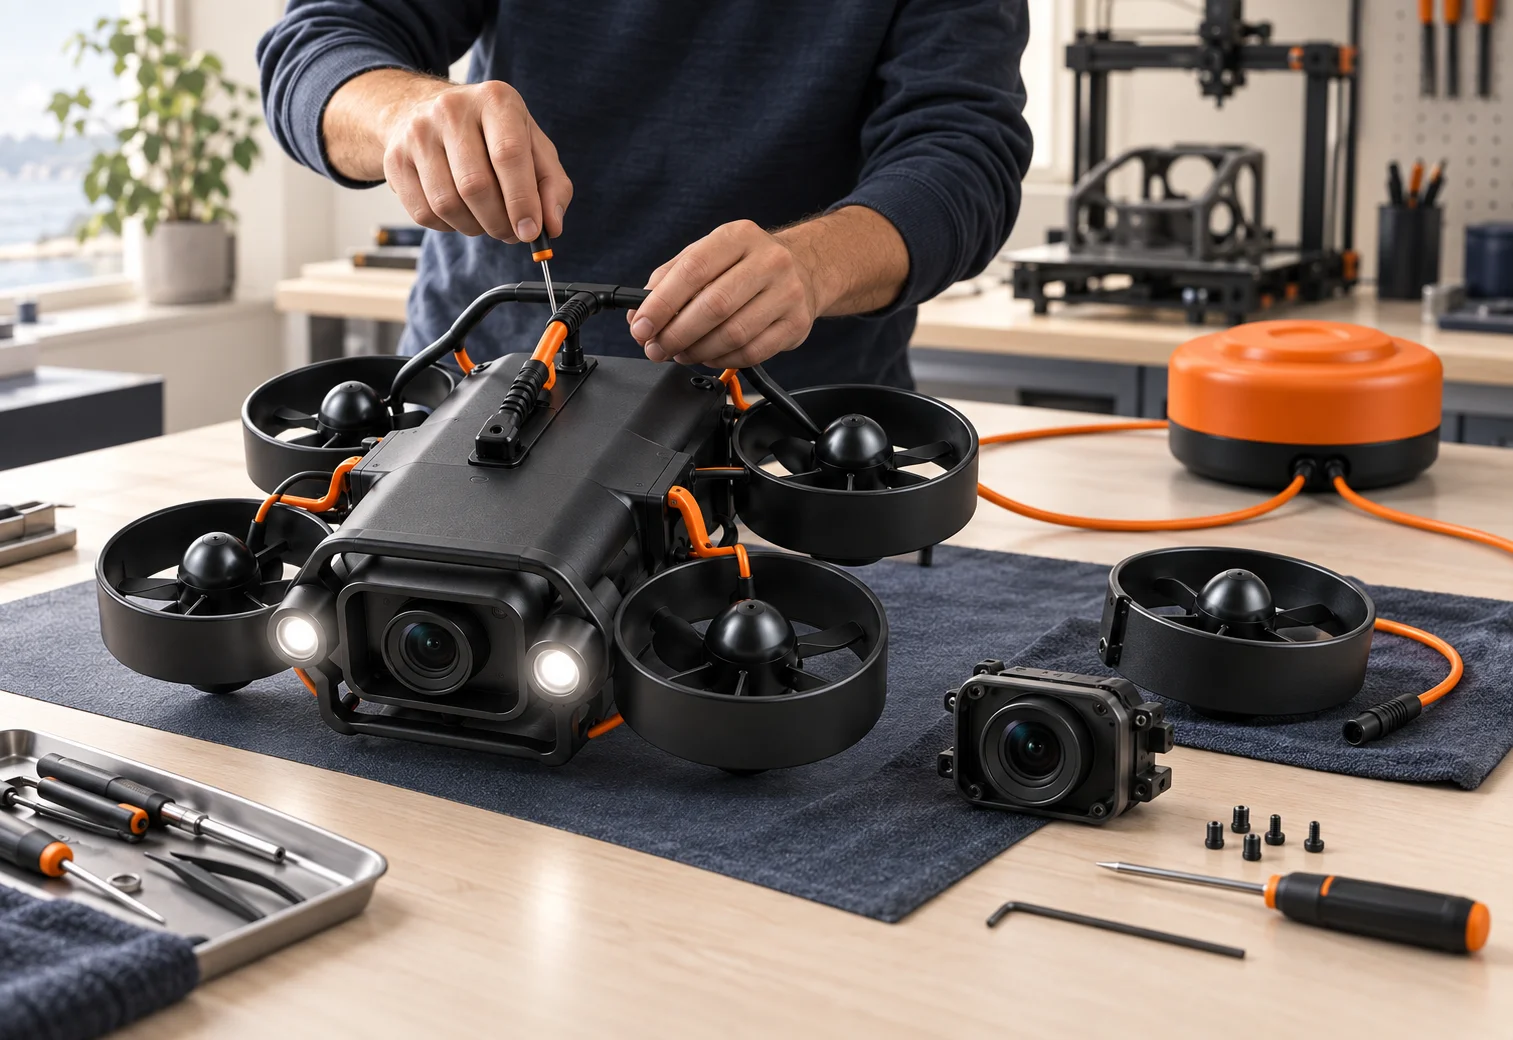
Replaceable components and accessible prototyping could let the hardware improve through real use.
A proposed Community Edition would bring together printable parts, a bill of materials, firmware and assembly guidance. Makers could help investigate thruster geometry, materials, tether handling and control feel.
For operators, modularity is practical: inspect a component, replace what needs attention and prepare for the next deployment. Pressure-balanced electronics are an engineering approach to investigate, with compatibility and pressure testing still ahead.
Community files, SDKs and guides are proposed deliverables, not released resources.
Trust starts with the design
A host manages the experience. A field operator stays responsible for what happens at the site.
Control is designed to pass through a clear handover. Onboard stabilization handles the fast corrections, while local priority and command timeouts address interruptions in the remote connection.
Recovery is a set of engineering questions to validate. No single mechanism removes the risk of loss or entanglement.
The vehicle is intended to be slightly positively buoyant. Prototype work would test how it behaves when propulsion stops, alongside locally controlled ascent. Conditions and entanglement can still prevent a return.
Releasable ballast is a proposed mechanical recovery layer. Later work includes emergency flotation and independent control or reserve energy, so recovery is not tied to one normal system.
An emergency locator buoy is a different component from the normal communications hub. Its line would help locate a trapped device; it should not be assumed to lift the vehicle or guarantee retrieval.
Operators would inspect the tether, check equipment and service activated recovery components before reuse. Repeatability and maintenance burden belong in the validation programme.
Future research
Between human sessions, an autonomous operator could continue a bounded mission: observe, revisit points of interest and create a public stream under local supervision.
A participant’s turn would pause autonomous activity. The mission would be reassessed before continuing.
A future decision layer could choose where to look next, while local control handles movement within the mission’s limits.
Camera direction could slow down around a subject, adjust lighting and avoid repeating the same view. Wildlife distance comes first.
Recorded observations and human interventions could inform later development. Research starts by watching before acting autonomously.
Our roadmap
The next step is a working shallow-water prototype. Each stage is designed to answer a real question before expanding.
Validate movement, stability and useful live video in shallow water.
The first milestoneTest repeated operation and guest demand with local tourism partners.
Proposed next stepProve remote handover, connection quality and willingness to pay.
Planned developmentAdd locations and booking tools as supply and demand develop.
Long-term visionAutonomous exploration and camera direction between human sessions, within operator-approved limits.
Future researchThe next conversations
There is a difference between a compelling vision and a proven business. The next work connects the two through hardware trials and focused pilot experiences.
Discuss a pilot or investmentThe project is at concept and prototype-planning stage. The first milestone is useful shallow-water piloting and video, followed by repeated operation and carefully scoped commercial pilots. The images on this page are design studies.
Real piloting is central to the proposal. A remote participant would command direction and movement; onboard software would stabilize the vehicle. Viewers could watch the same exploration without having control.
Local control at a shore, pier or boat is a core design goal. Internet connectivity would add remote participation and public streaming. A boat-side satellite uplink is a possible future option, not validated Remote Dive compatibility.
The starting concept is an underwater live view on a virtual screen inside a headset, with a game controller for piloting. Head-linked camera movement and stereo imagery are separate future experiments.
Proposed routes include hosted boat experiences, paid remote turns, private sessions and creator events. Revenue would depend on customer demand, operating conditions, staff time and equipment costs; no return is guaranteed.
Natural controls, useful footage, tether handling, repeatable recovery and equipment durability. Tourism pilots would then test the guest experience and workload. Remote sessions add connection quality, handovers and willingness to pay.
Let’s build what comes next
An early-stage venture seeking conversations
with investors and pilot partners.